Hardware & IoT
No visual example yet
Explore the skill
Isaac Ros Cumotion
NVIDIA-ISAAC-ROS
NVIDIA-accelerated packages for arm motion planning and control
255GitHub
OPENAGENTSKILL / DIRECTORY
Find a skill for your next task. Explore tools for Codex, Claude Code, Cursor and more.
Find a skill for your next task. Preview examples where available.
49–63 / 63
Results: 63
No visual example yet
Explore the skillNVIDIA-ISAAC-ROS
NVIDIA-accelerated packages for arm motion planning and control
No visual example yet
Explore the skillmees
CALVIN - A benchmark for Language-Conditioned Policy Learning for Long-Horizon Robot Manipulation Tasks
No visual example yet
Explore the skillRoboStack
Jupyter widget helpers for ROS, the Robot Operating System
No visual example yet
Explore the skillproroklab
VMAS is a vectorized differentiable simulator designed for efficient Multi-Agent Reinforcement Learning benchmarking. It is comprised of a vectorized 2D physics engine w…
No visual example yet
Explore the skillori-drs
Pronto - Legged Robot State Estimator - libraries, ROS wrapper and messages
No visual example yet
Explore the skillTaeyoung96
[RA-L 2024] GRIL-Calib: Targetless Ground Robot IMU-LiDAR Extrinsic Calibration Method using Ground Plane Motion Constraints
No visual example yet
Explore the skillMechanical-Advantage
Robot telemetry application
No visual example yet
Explore the skilluos
Mobile Robot Localization in 3D Triangle Meshes & Geometric Scene Graphs
No visual example yet
Explore the skillEkumen-OS
Open-source diff drive robot ROS 2 compatible
No visual example yet
Explore the skillMizuhoAOKI
[IROS 2024] MPPI (Model Predictive Path-Integral) Controller for a Swerve Drive Robot
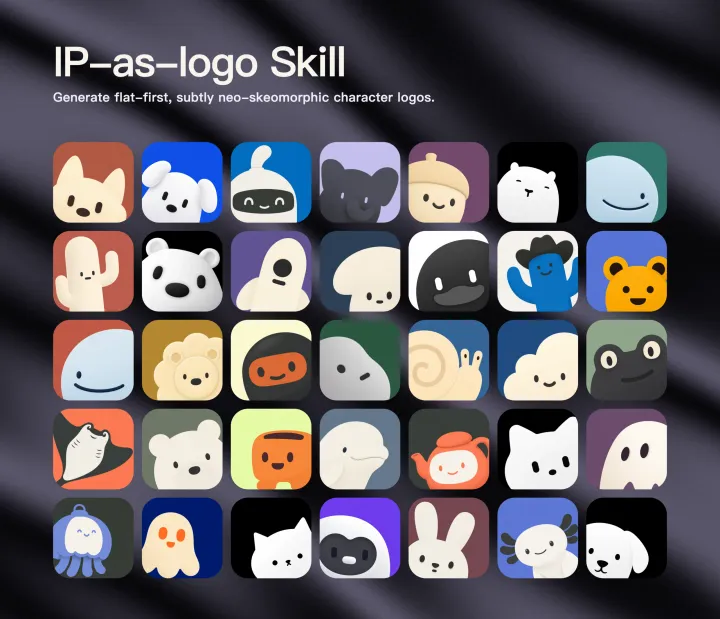
s1dashu
Generate highly simplified personified IP mascot logos with Flat-first geometry, rounded heavy forms, two IP colors plus one background color by default, and extremely s…
View examples · 1No visual example yet
Explore the skillearthtojake
MoveIt2 SRDF authoring, validation, and planning-semantics workflow. Use when creating, editing, inspecting, or validating `.srdf` files, MoveIt planning groups, virtual…
No visual example yet
Explore the skillearthtojake
Start CAD Viewer and return review links for explicit CAD, implicit CAD, and robot-description files. Use when visually reviewing `.step`, `.stp`, `.implicit.js`, `.impl…
No visual example yet
Explore the skillearthtojake
URDF robot description authoring and validation. Use when creating, editing, inspecting, validating, or debugging `.urdf` files, robot links, joints, limits, inertials,…
No visual example yet
Explore the skillmajiayu000
Use when you need to install the embedded robot agents into either .cursor/agents or .claude/agents, selecting the destination interactively and copying the embedded age…


