No visual example yet
Explore the skillSimplerEnv
simpler-env
Evaluating and reproducing real-world robot manipulation policies (e.g., RT-1, RT-1-X, Octo) in simulation under common setups (e.g., Google Robot, WidowX+Bridge) (CoRL…
OPENAGENTSKILL / DIRECTORY
Find a skill for your next task. Explore tools for Codex, Claude Code, Cursor and more.
24 Skills
Results: 24
No visual example yet
Explore the skillsimpler-env
Evaluating and reproducing real-world robot manipulation policies (e.g., RT-1, RT-1-X, Octo) in simulation under common setups (e.g., Google Robot, WidowX+Bridge) (CoRL…
No visual example yet
Explore the skillchonyy
:basketball::robot::basketball: AI web app and API to analyze basketball shots and shooting pose.
No visual example yet
Explore the skillBR-IDL
:robot: PaddleViT: State-of-the-art Visual Transformer and MLP Models for PaddlePaddle 2.0+
No visual example yet
Explore the skillusdot-fhwa-stol
CARMA Platform is built on robot operating system (ROS) and utilizes open source software (OSS) that enables Cooperative Driving Automation (CDA) features to allow Autom…

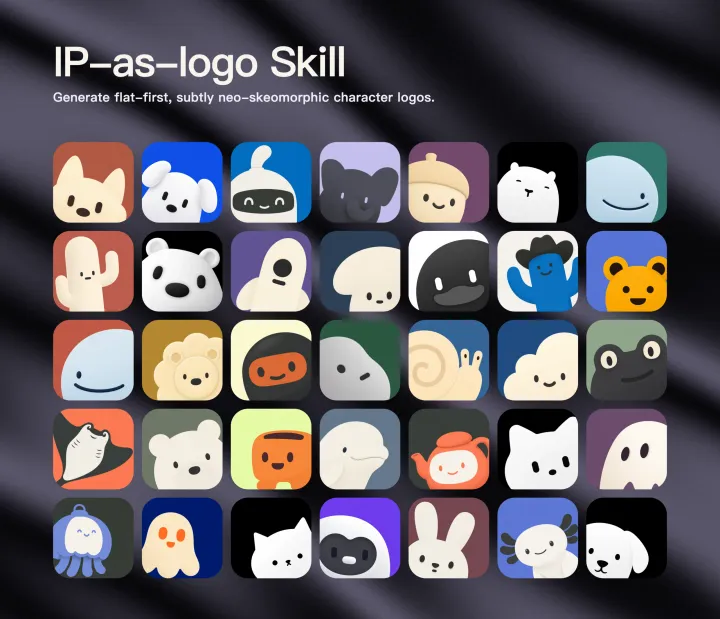
s1dashu
Generate highly simplified personified IP mascot logos with Flat-first geometry, rounded heavy forms, two IP colors plus one background color by default, and extremely s…
View examples · 1No visual example yet
Explore the skillearthtojake
MoveIt2 SRDF authoring, validation, and planning-semantics workflow. Use when creating, editing, inspecting, or validating `.srdf` files, MoveIt planning groups, virtual…
No visual example yet
Explore the skillearthtojake
Start CAD Viewer and return review links for explicit CAD, implicit CAD, and robot-description files. Use when visually reviewing `.step`, `.stp`, `.implicit.js`, `.impl…
No visual example yet
Explore the skillearthtojake
URDF robot description authoring and validation. Use when creating, editing, inspecting, validating, or debugging `.urdf` files, robot links, joints, limits, inertials,…