Hardware & IoT
No visual example yet
Explore the skill
PaddleViT
BR-IDL
:robot: PaddleViT: State-of-the-art Visual Transformer and MLP Models for PaddlePaddle 2.0+
1.2KGitHub
OPENAGENTSKILL / DIRECTORY
Find a skill for your next task. Explore tools for Codex, Claude Code, Cursor and more.
Find a skill for your next task. Preview examples where available.
33–45 / 45
Results: 45
No visual example yet
Explore the skillBR-IDL
:robot: PaddleViT: State-of-the-art Visual Transformer and MLP Models for PaddlePaddle 2.0+
No visual example yet
Explore the skillArduPilot
APM Planner Ground Control Station (Qt)
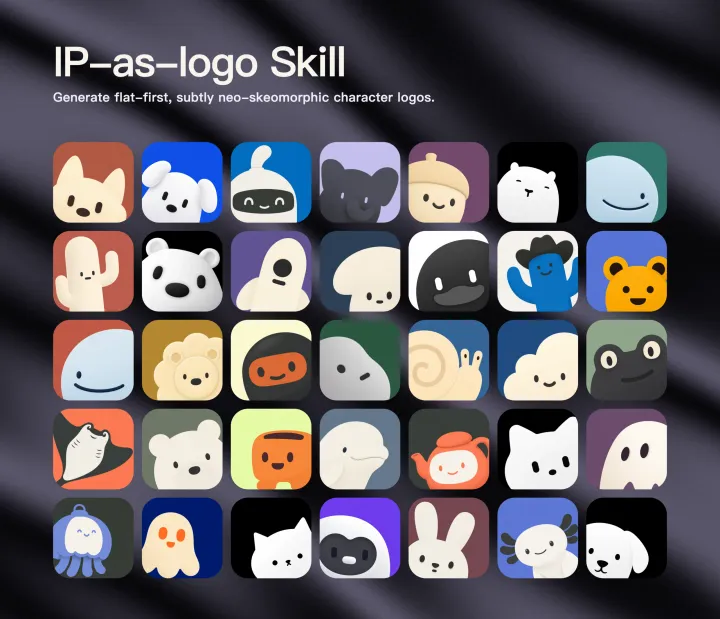
s1dashu
Generate highly simplified personified IP mascot logos with Flat-first geometry, rounded heavy forms, two IP colors plus one background color by default, and extremely s…
View examples · 1No visual example yet
Explore the skillusdot-fhwa-stol
CARMA Platform is built on robot operating system (ROS) and utilizes open source software (OSS) that enables Cooperative Driving Automation (CDA) features to allow Autom…
No visual example yet
Explore the skillRoboStack
Jupyter widget helpers for ROS, the Robot Operating System
No visual example yet
Explore the skillproroklab
VMAS is a vectorized differentiable simulator designed for efficient Multi-Agent Reinforcement Learning benchmarking. It is comprised of a vectorized 2D physics engine w…
No visual example yet
Explore the skillori-drs
Pronto - Legged Robot State Estimator - libraries, ROS wrapper and messages
No visual example yet
Explore the skillMechanical-Advantage
Robot telemetry application
No visual example yet
Explore the skilluos
Mobile Robot Localization in 3D Triangle Meshes & Geometric Scene Graphs
No visual example yet
Explore the skillmalintha
A drone swarm simulator based on ROS (Robot Operating System).
No visual example yet
Explore the skillearthtojake
MoveIt2 SRDF authoring, validation, and planning-semantics workflow. Use when creating, editing, inspecting, or validating `.srdf` files, MoveIt planning groups, virtual…
No visual example yet
Explore the skillearthtojake
Start CAD Viewer and return review links for explicit CAD, implicit CAD, and robot-description files. Use when visually reviewing `.step`, `.stp`, `.implicit.js`, `.impl…
No visual example yet
Explore the skillearthtojake
URDF robot description authoring and validation. Use when creating, editing, inspecting, validating, or debugging `.urdf` files, robot links, joints, limits, inertials,…


