Guide on how to set-up Linux and Docker for real-time applications using the Ubuntu realtime-kernel/PREEMPT_RT patch with a focus on robotics with ROS and ROS 2
Guide on how to set-up Linux and Docker for real-time applications using the Ubuntu realtime-kernel/PREEMPT_RT patch with a focus on robotics with ROS and ROS 2
Imported by the skill-only GitHub discovery pipeline because it matches agent skill, automation, domain workflow, RAG, document-processing, data, finance, security, or developer-tool signals. Protocol-server projects are excluded from automated imports.
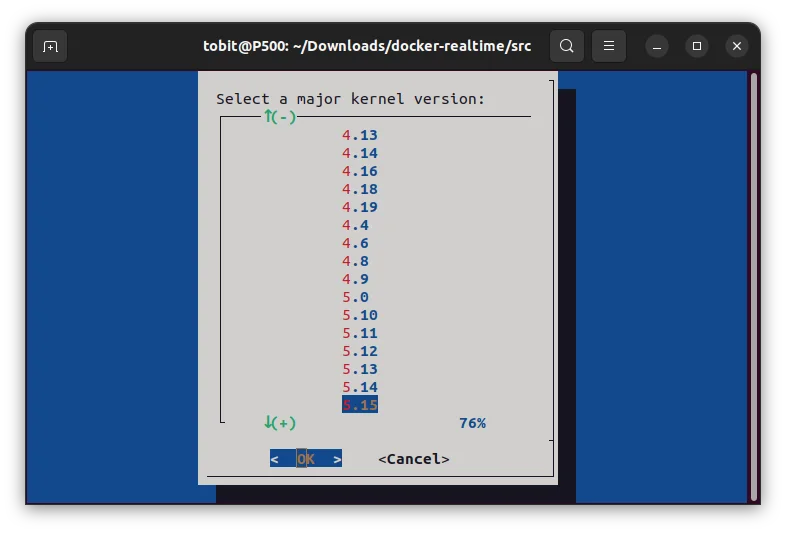
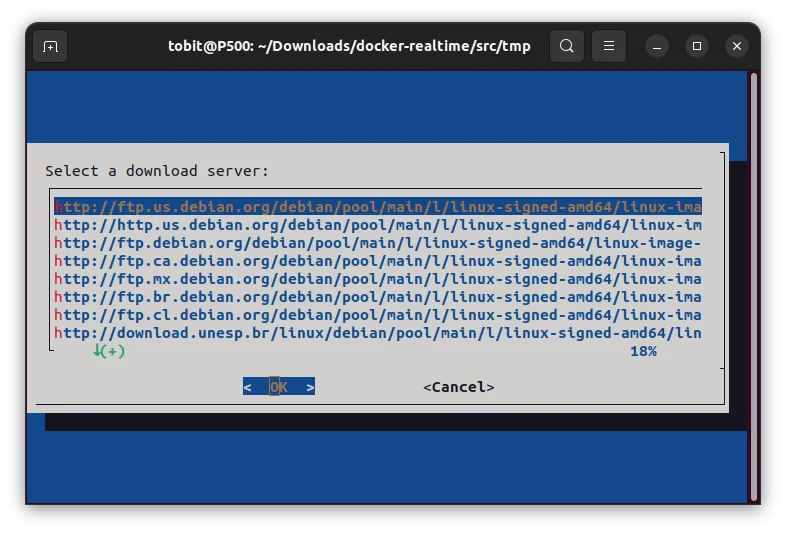
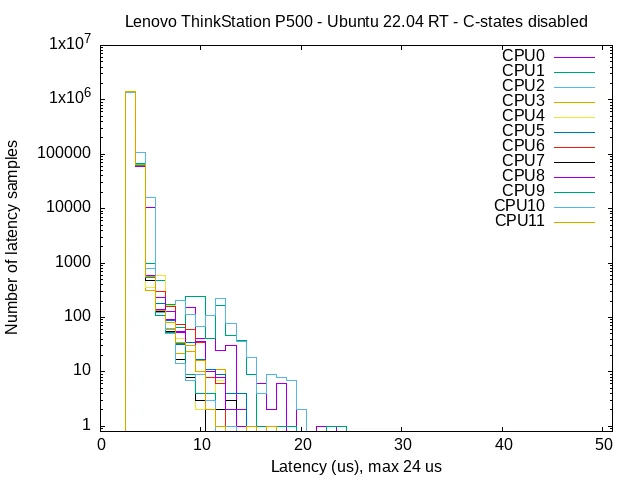
先看看实际效果
浏览作者提供的图片与示例。打开原始文件,可查看完整尺寸的作品和动图。
Linux Realtime · 作者预览 · 原始来源 · MIT · 许可Linux Realtime · 作者预览 · 原始来源 · MIT · 许可Linux Realtime · 作者预览 · 原始来源 · MIT · 许可